
EgoHumanoid-V2: Human-to-Humanoid Transfer of Coordinated Whole-Body Skills for Loco-Manipulation
The first egocentric human-to-humanoid skill transfer framework for coordinated whole-body loco-manipulation
Highlights
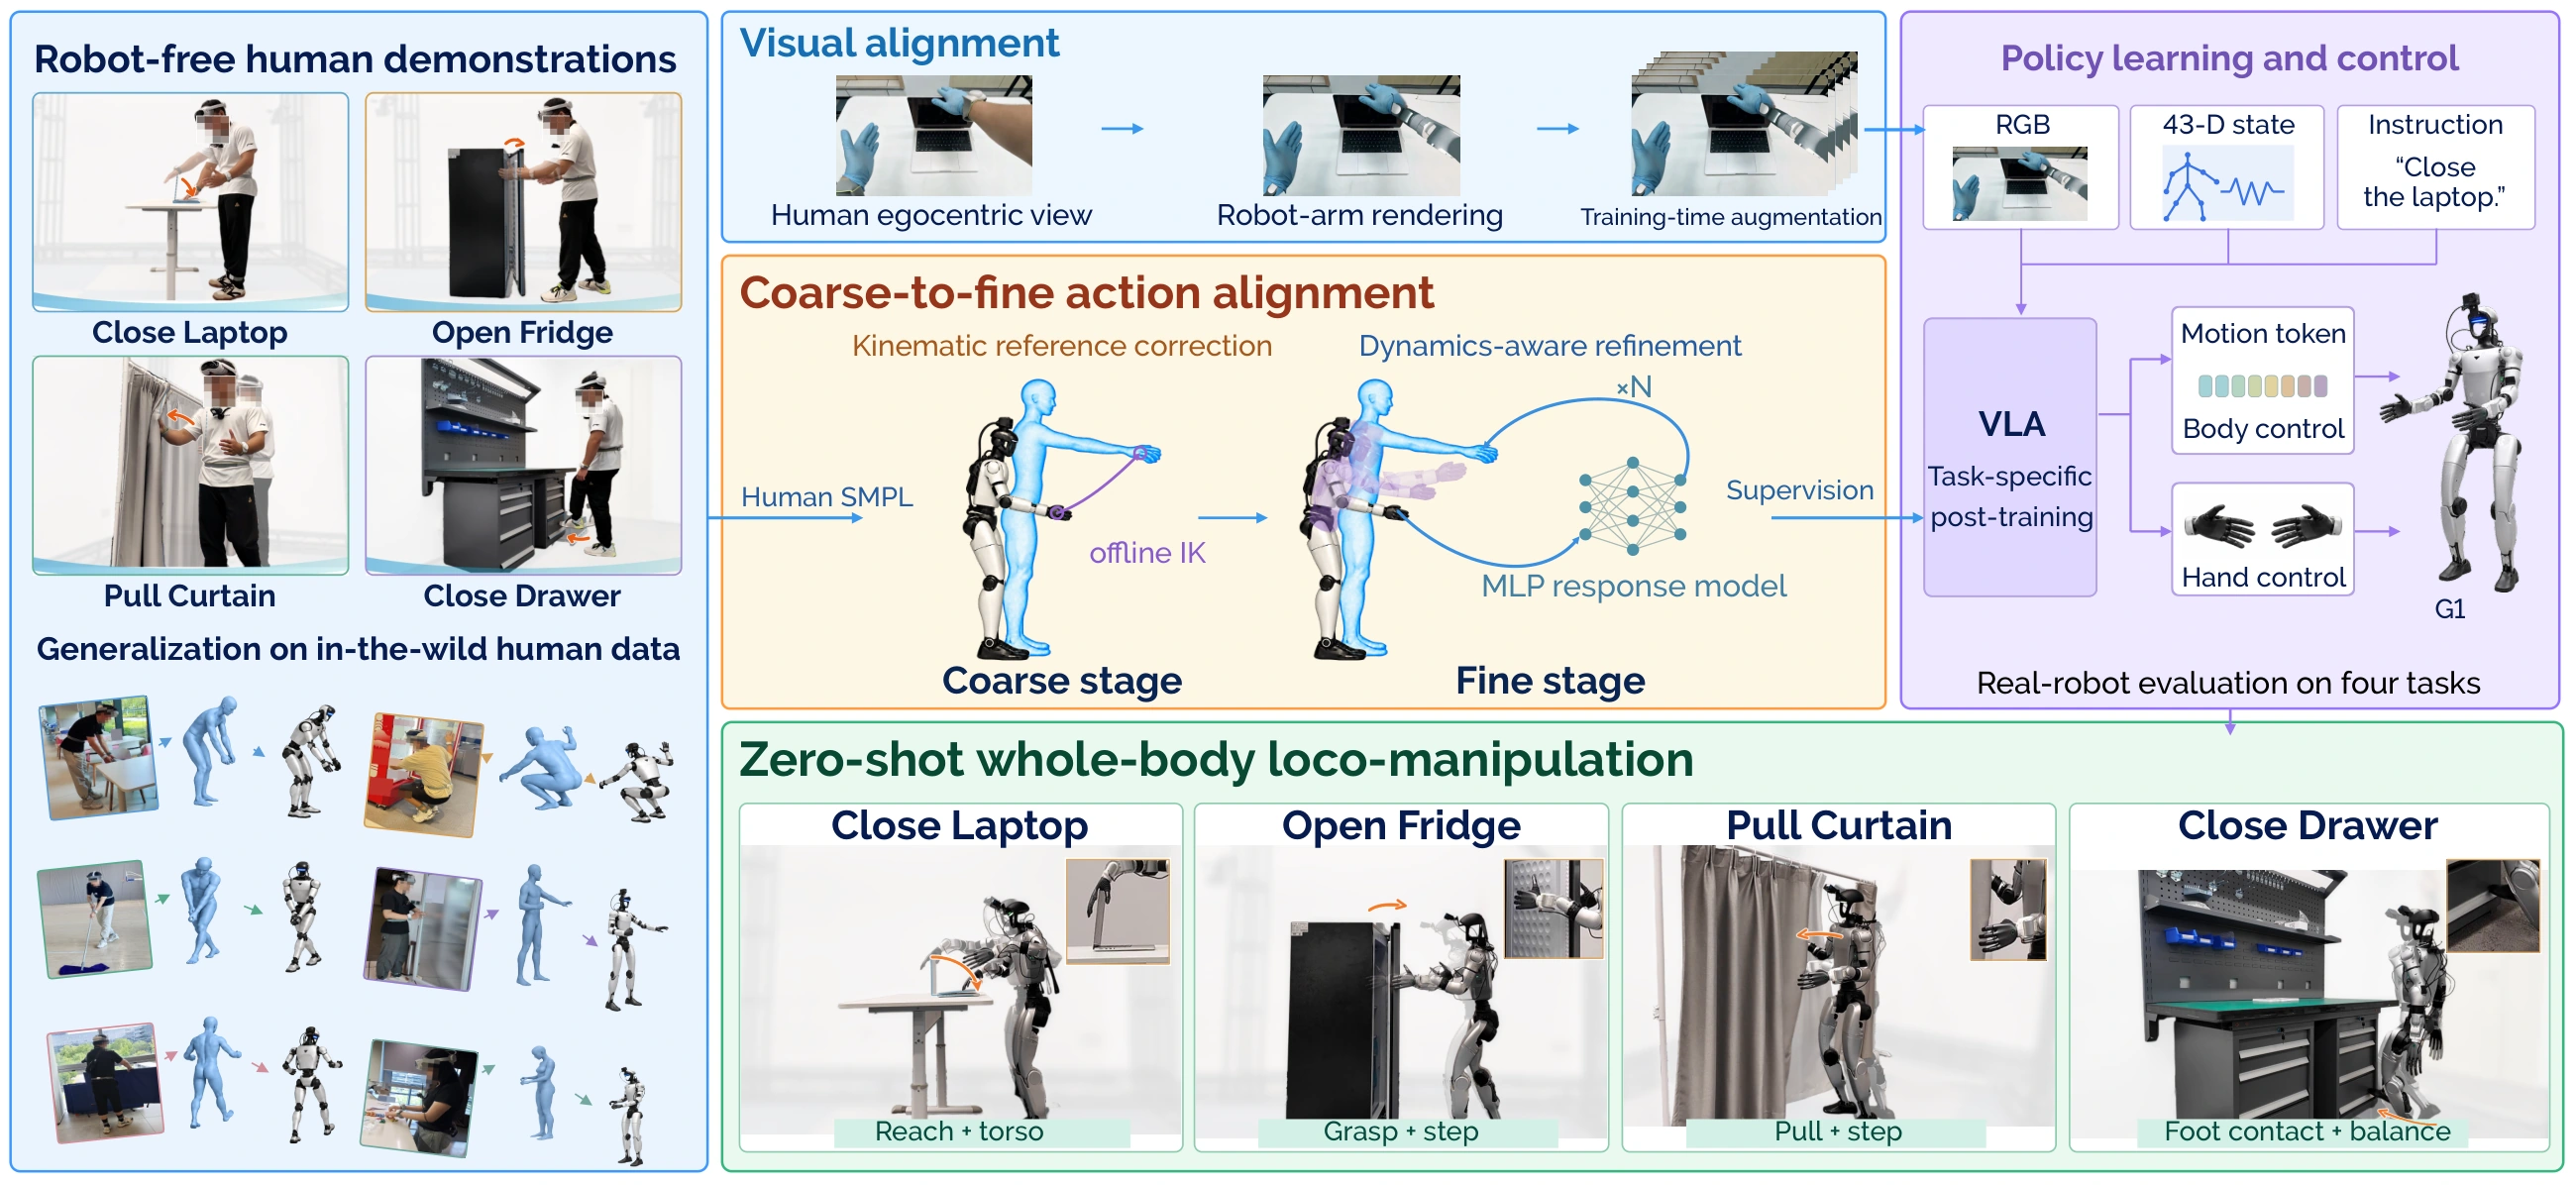
- The first egocentric human-to-humanoid skill transfer framework for coordinated whole-body loco-manipulation.
- Coarse-to-fine action alignment combines kinematic reference correction with dynamics-aware refinement.
- Zero-shot skill transfer on four real-world tasks, with analyses of accuracy, policy scores, and collection cost.
Results
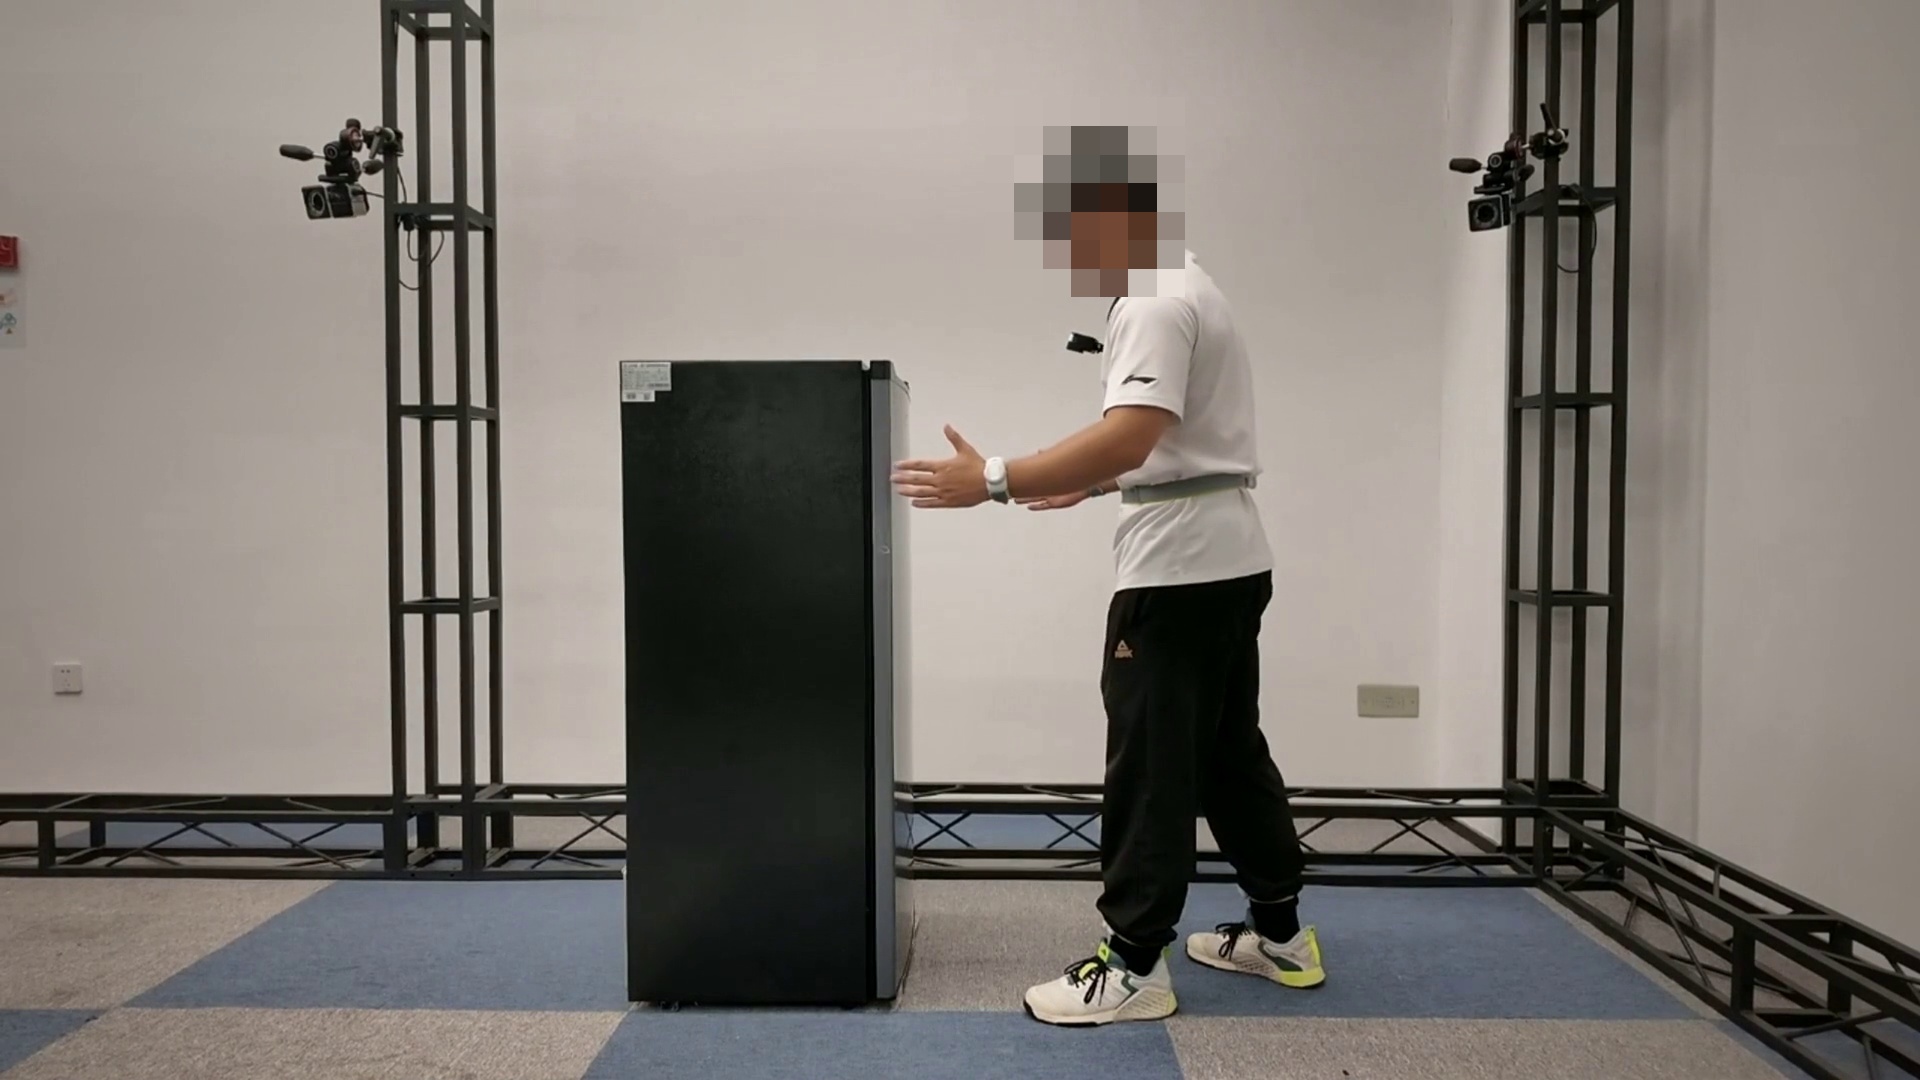
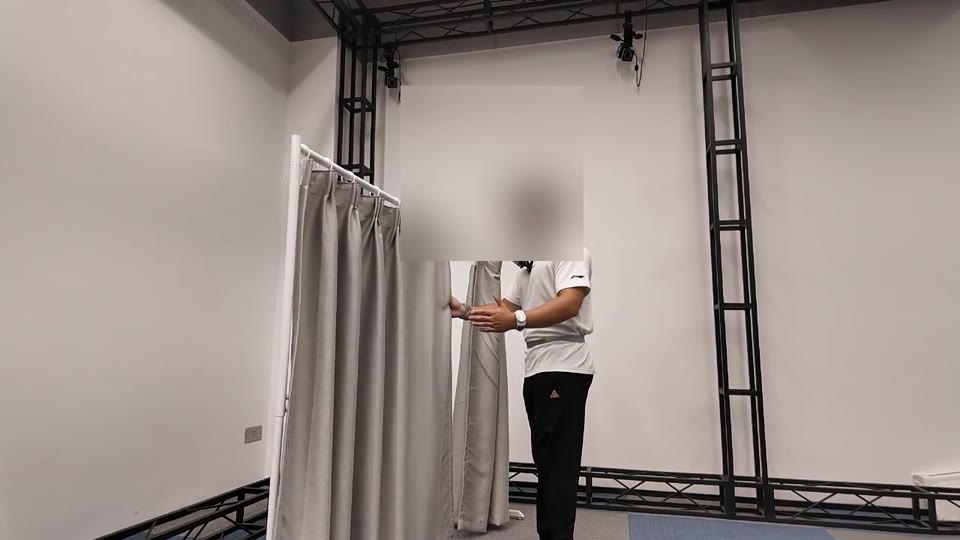
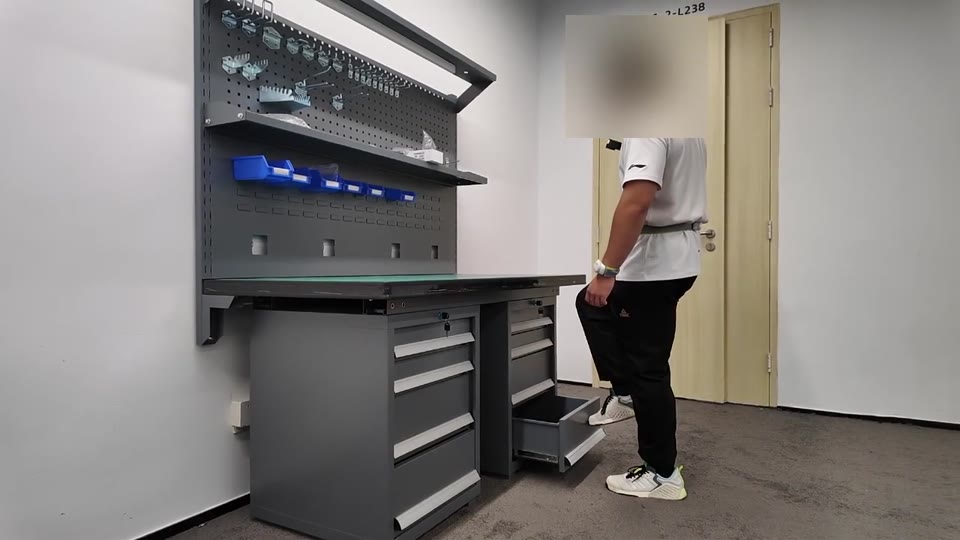
Human Data Collection
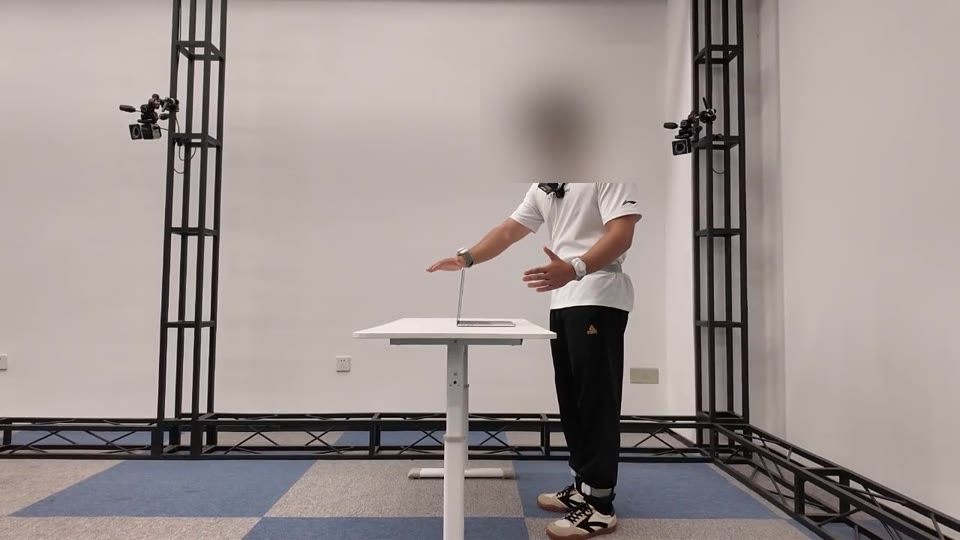
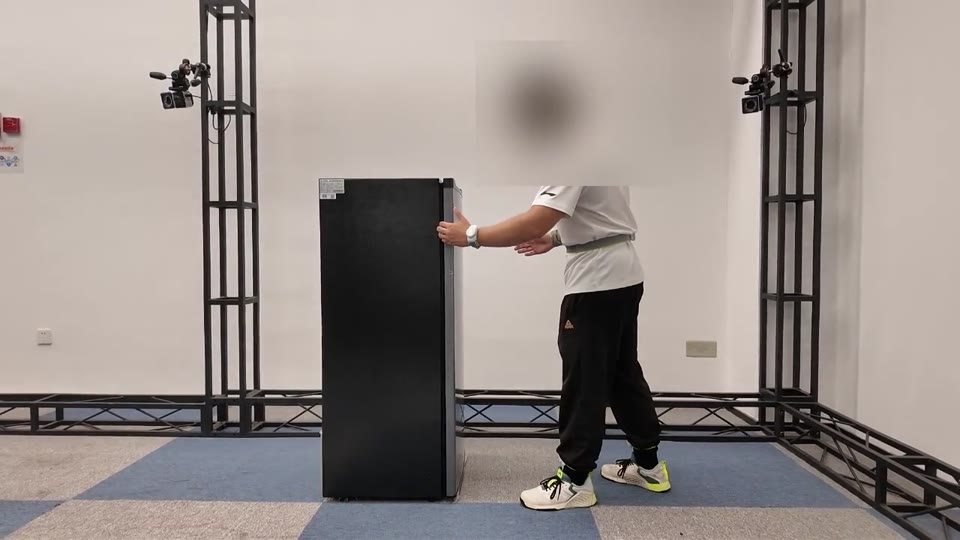
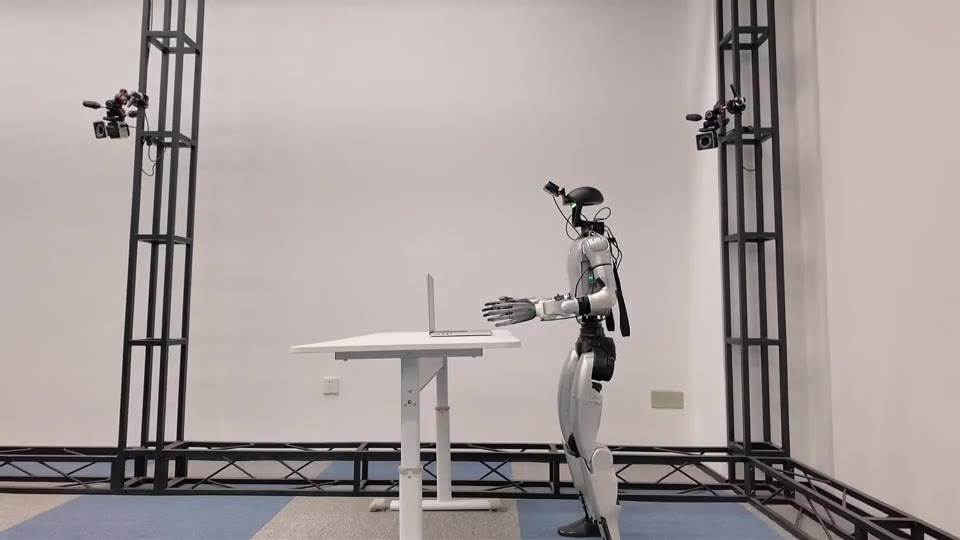
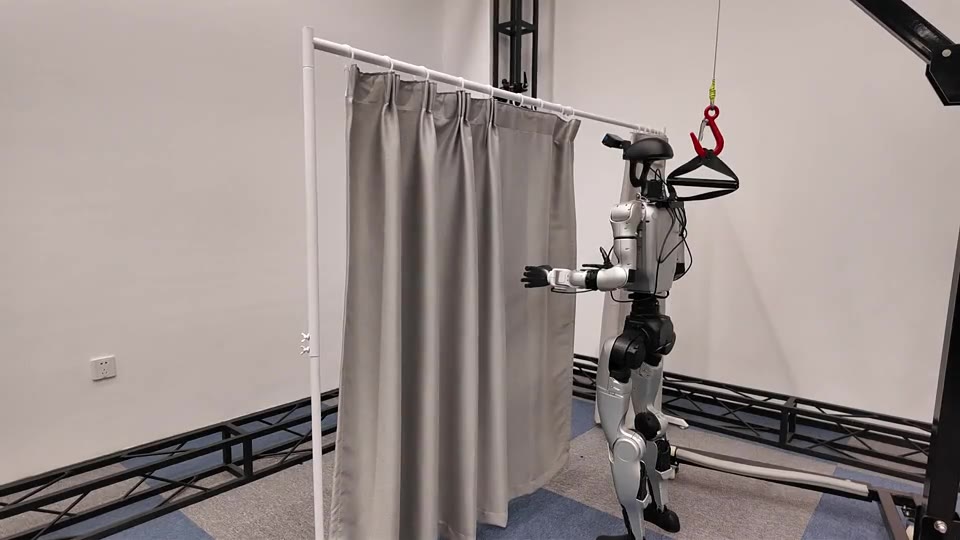
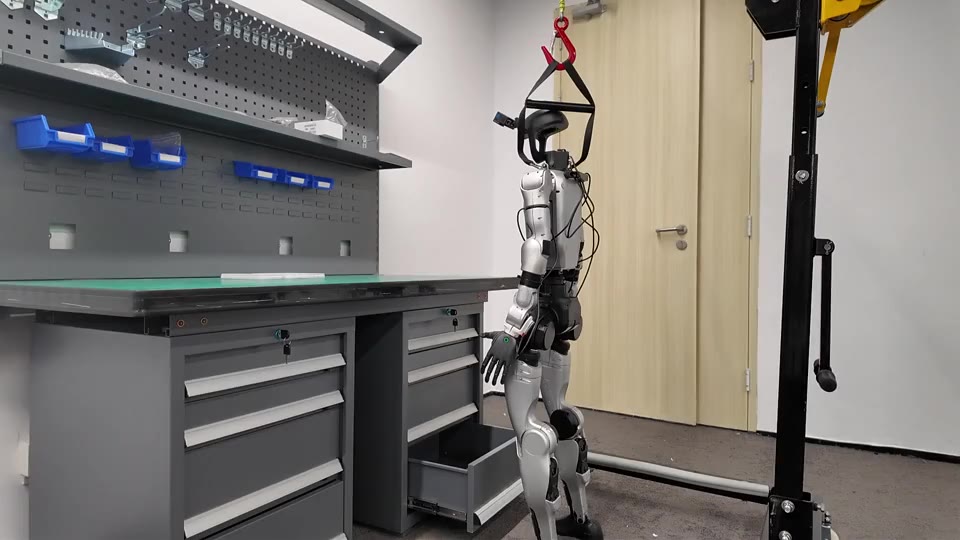
Unaligned Data · Replay
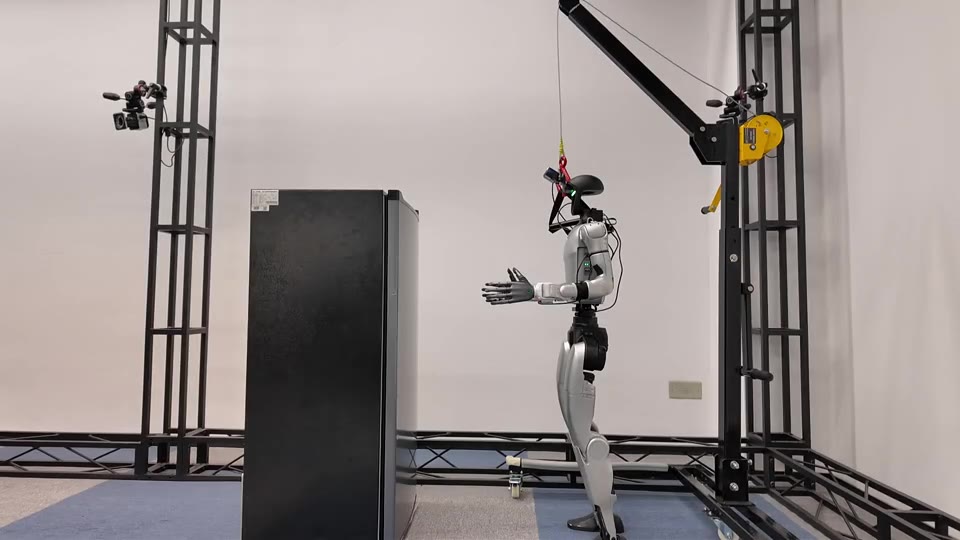
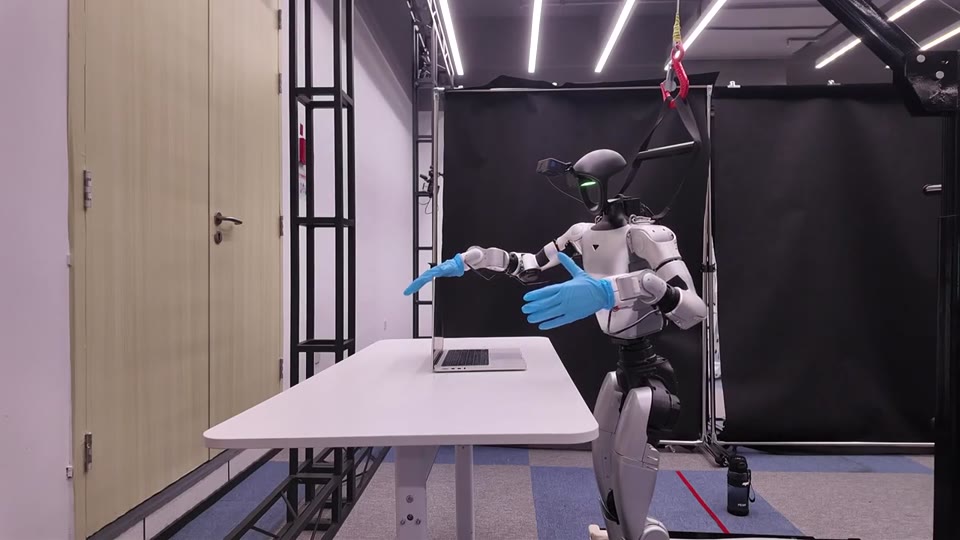
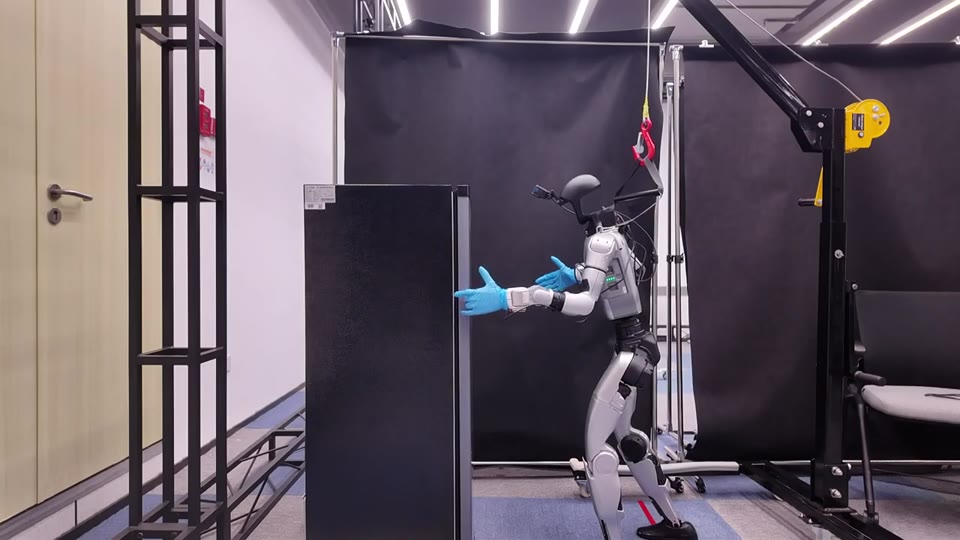
Aligned Data · Inference
Scaling Human Demonstrations
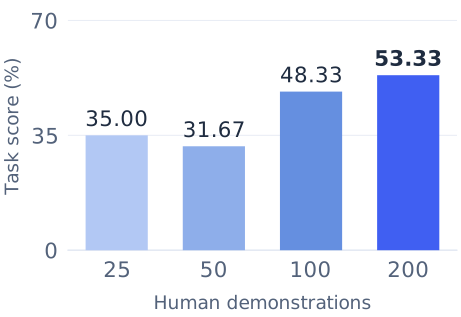
Close Laptop
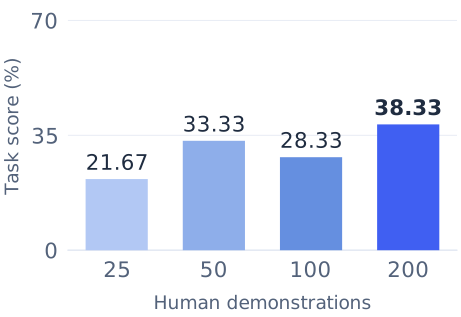
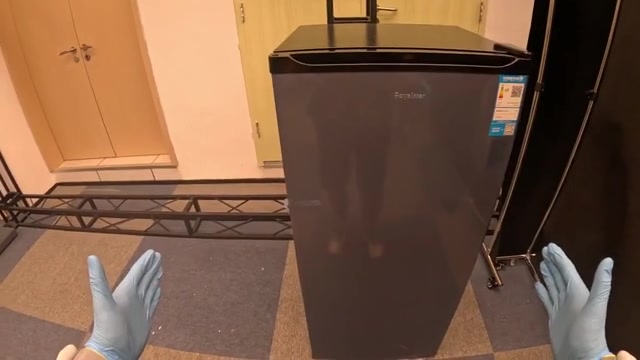
Open Fridge
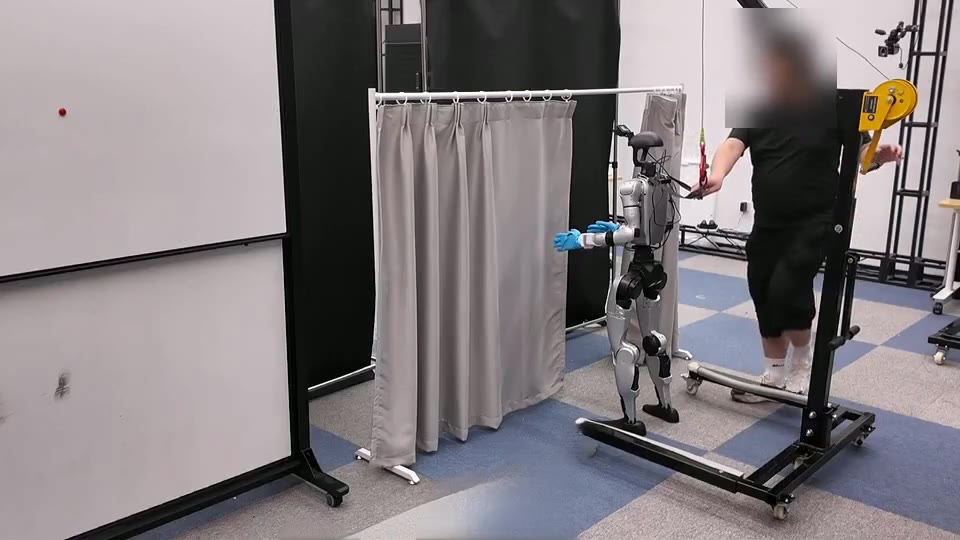
Pull Curtain
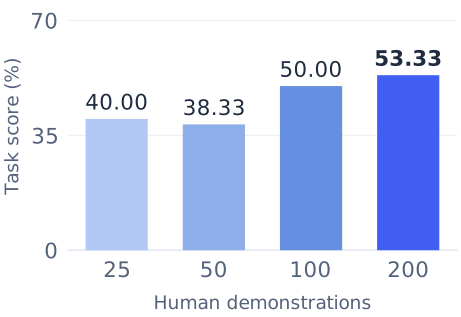
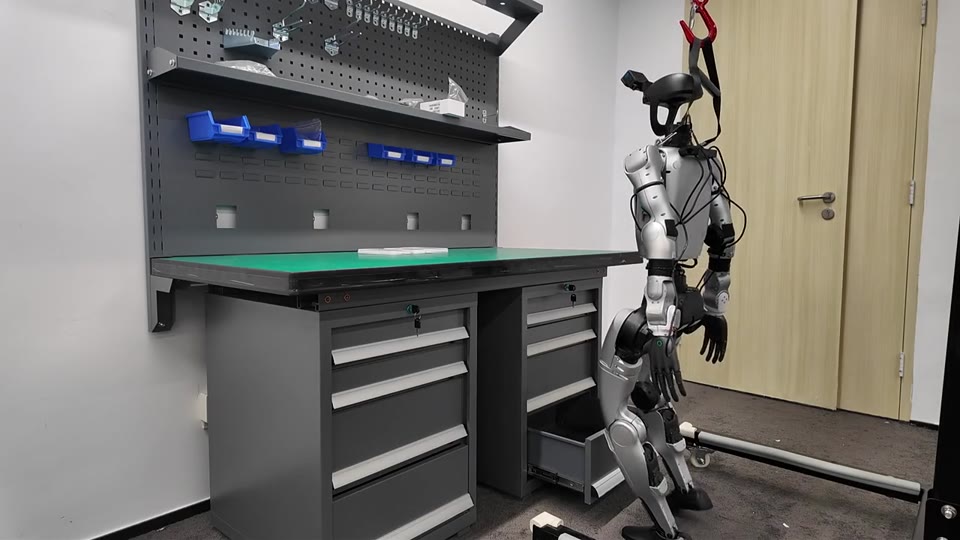
Close Drawer
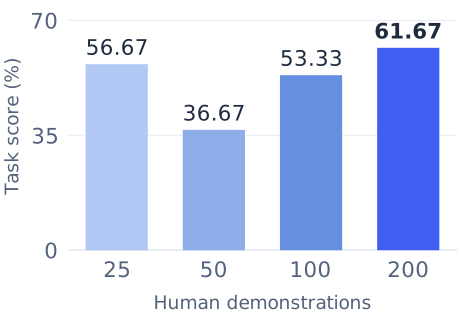
Task scores by demonstration count
| Human demos / task | Close Laptop | Open Refrigerator | Pull Curtain | Close Drawer |
|---|---|---|---|---|
| 25 | 35.00 | 21.67 | 40.00 | 56.67 |
| 50 | 31.67 | 33.33 | 38.33 | 36.67 |
| 100 | 48.33 | 28.33 | 50.00 | 53.33 |
| 200 | 53.33 | 38.33 | 53.33 | 61.67 |
Action Alignment
H: Initial SONIC rolloutK: Kinematic reference correctionD: Dynamics-aware refinement
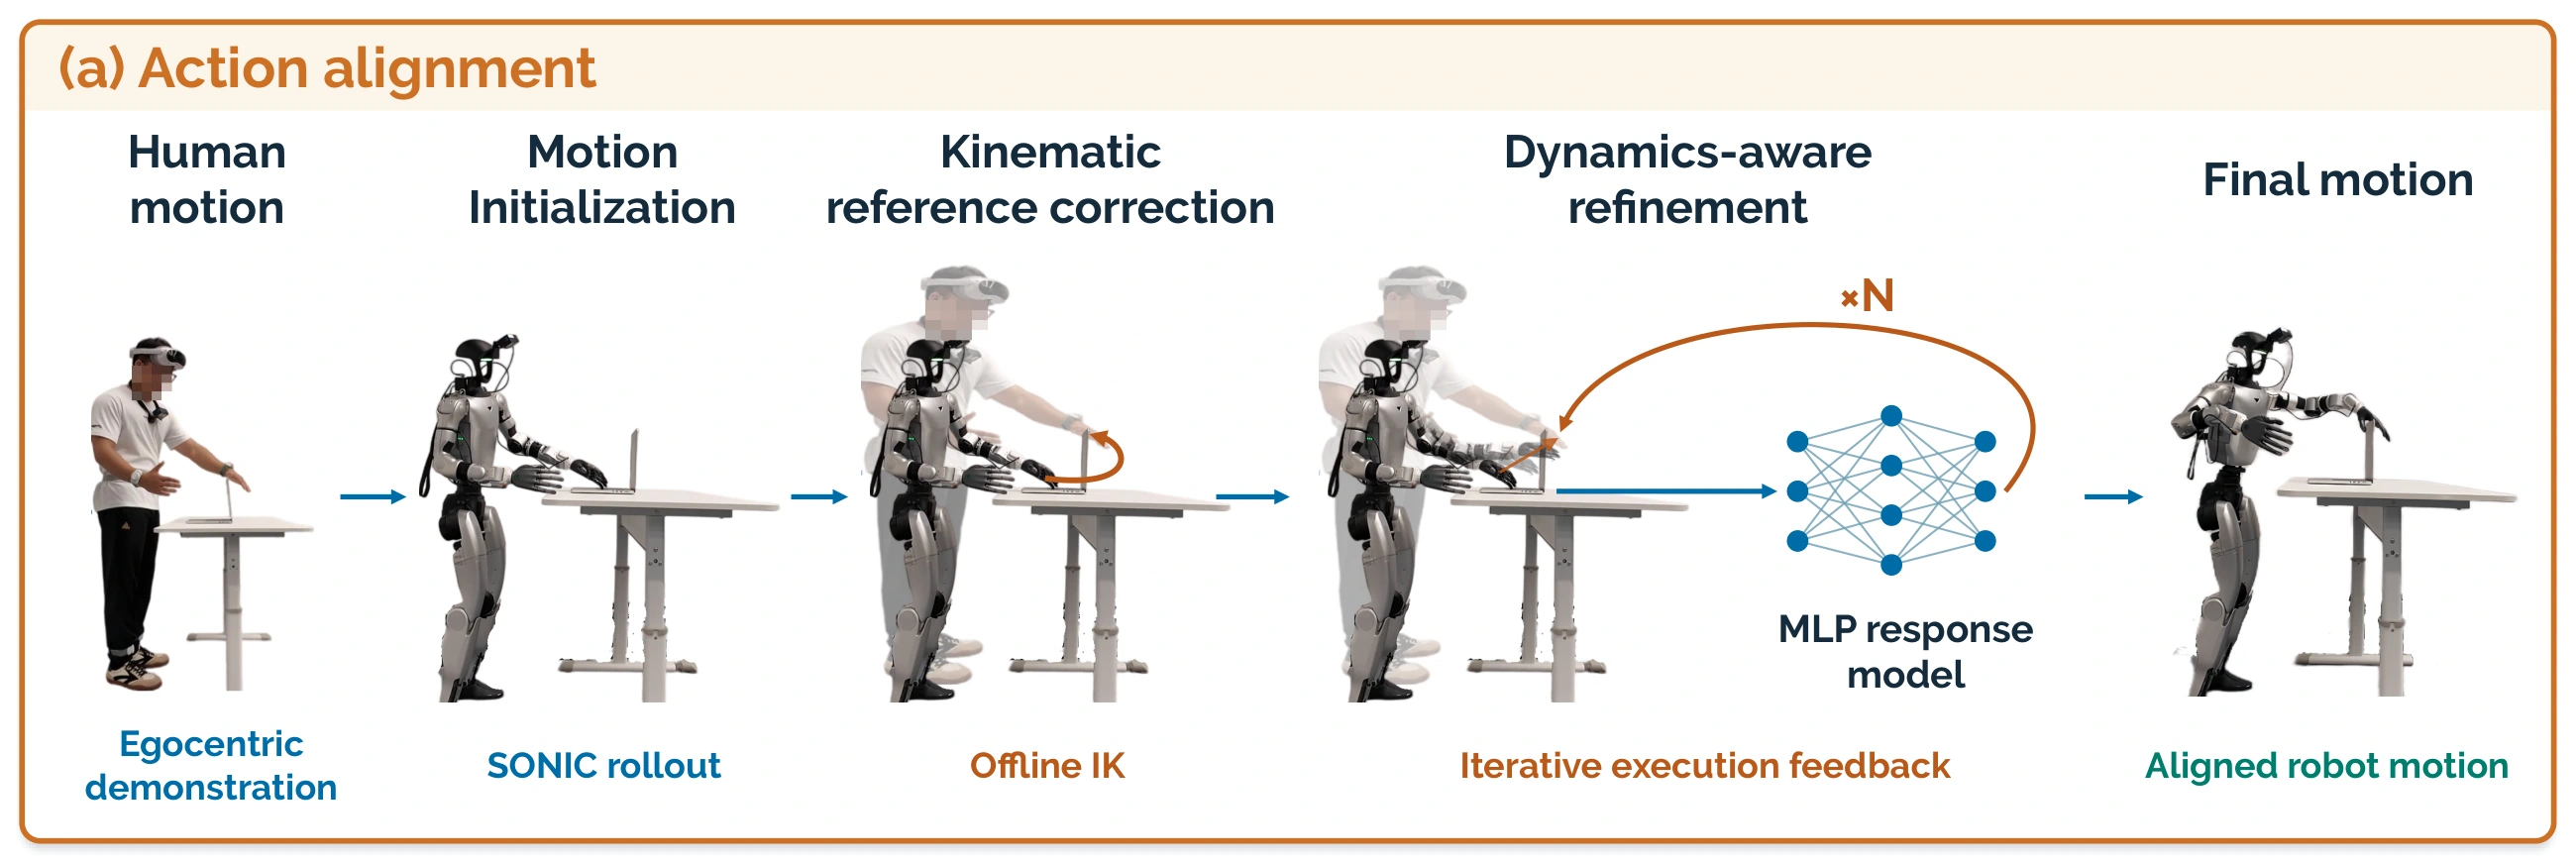
Mean task score21.25%
Position error11.21 cm
Orientation error21.22°
Mean score ↑
Endpoint error ↓
| Stage | Position (cm) | Orientation (°) |
|---|---|---|
| H | 11.21 | 21.22 |
| H + K | 4.45 | 13.77 |
| H + K + Ds | 3.41 | 6.71 |
Task scores
| Action alignment | Close Laptop | Open Refrigerator | Pull Curtain | Close Drawer | Mean |
|---|---|---|---|---|---|
| H | 0.00 | 0.00 | 28.33 | 56.67 | 21.25 |
| H + K | 46.67 | 31.67 | 51.67 | 58.33 | 47.08 |
| H + K + Ds | 53.33 | 38.33 | 53.33 | 61.67 | 51.67 |
Visual Alignment
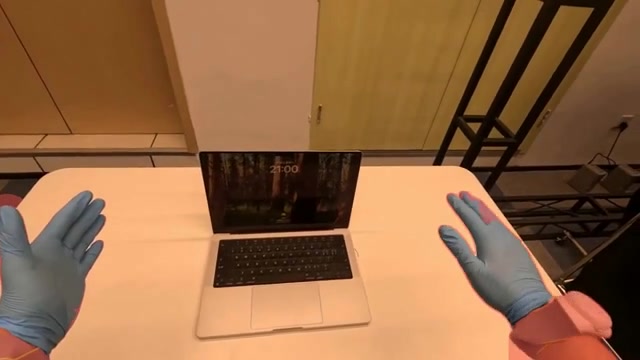
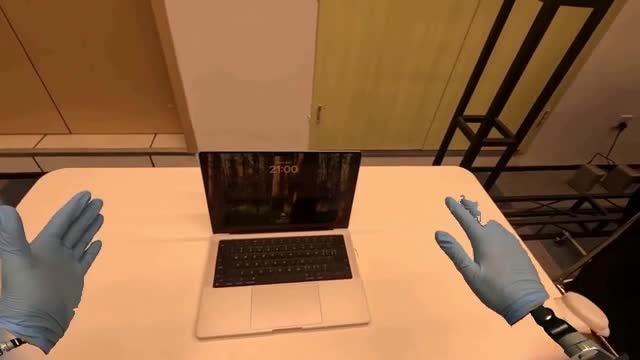
Close Laptop
Open Fridge
Pull Curtain
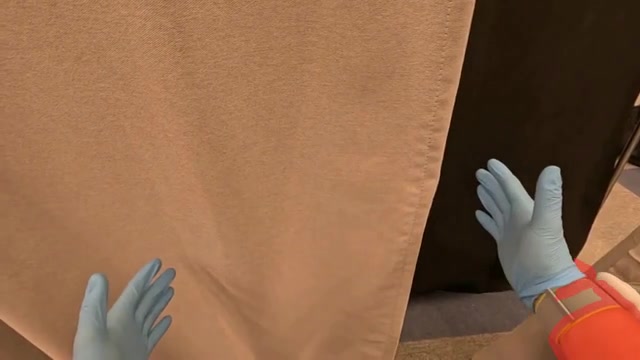
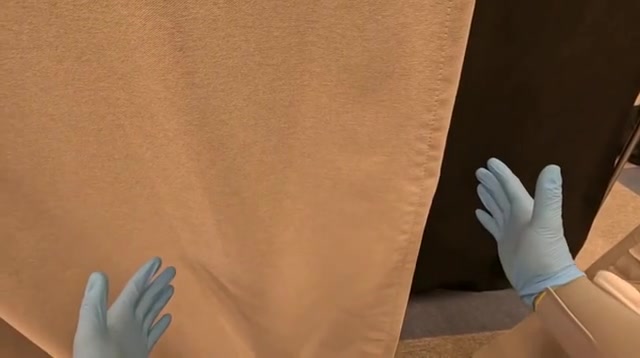
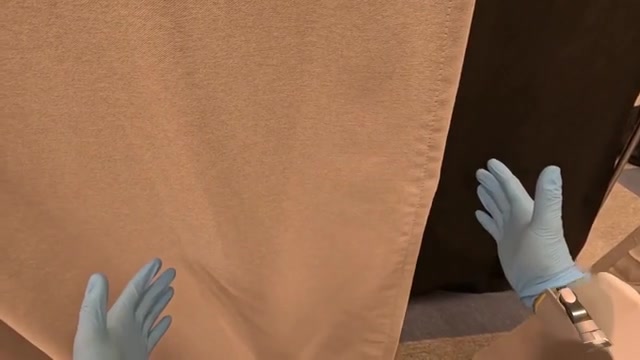
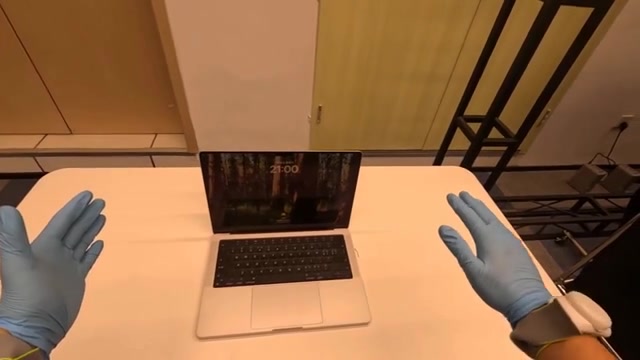
Visual alignment results
| Training images | Close Laptop | Open Refrigerator | Pull Curtain | Close Drawer |
|---|---|---|---|---|
| Human RGB | 31.67 | 16.67 | 35.00 | 50.00 |
| + Arm rendering | 51.67 | 23.33 | 41.67 | — |
| + Augmentation | 61.67 | 33.33 | 33.33 | 61.67 |
| + Both | 53.33 | 38.33 | 53.33 | — |
Task scores with 200 human demonstrations. Arm rendering is not evaluated for foot-operated drawer closing.
BibTeX Citation
@article{chen2026egohumanoidv2,
    title={{EgoHumanoid-V2}: Human-to-Humanoid Transfer of Coordinated Whole-Body Skills for Loco-Manipulation},
    author={Chen, Jin and Jiang, Yiming and Xu, Chongyang and Shi, Modi and Peng, Shijia and Chen, Li and Li, Tianyu and Xu, Mu and Chen, Yilun and Hoi, Steven and Li, Hongyang},
    journal={arXiv preprint arXiv:2609.37181},
    year={2026}
}