1 / 8
Preprint 2026
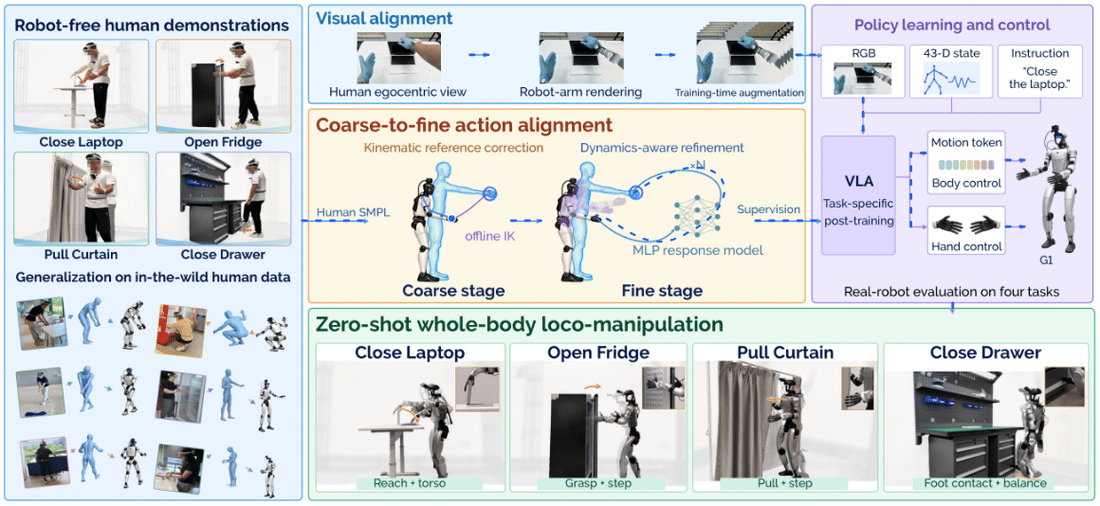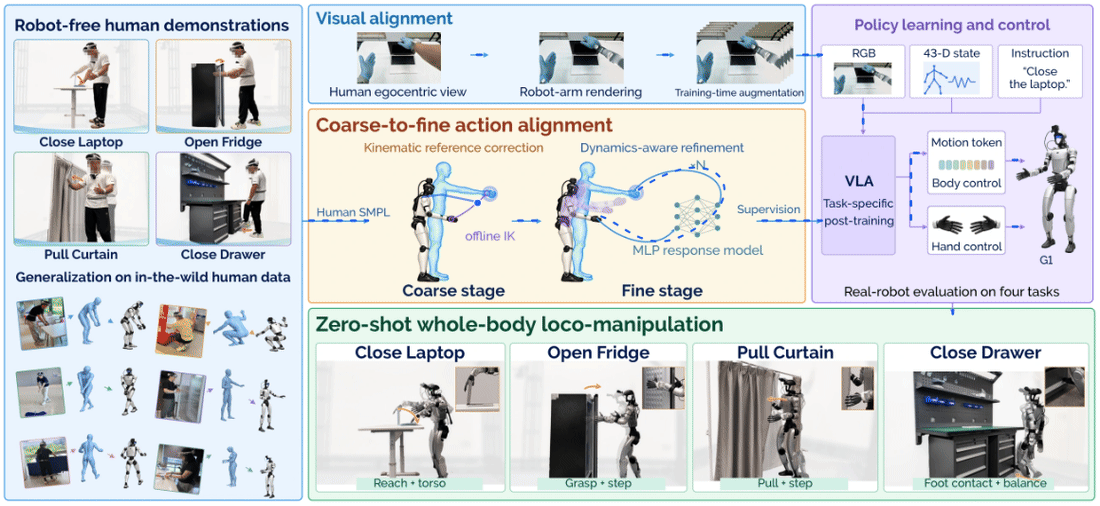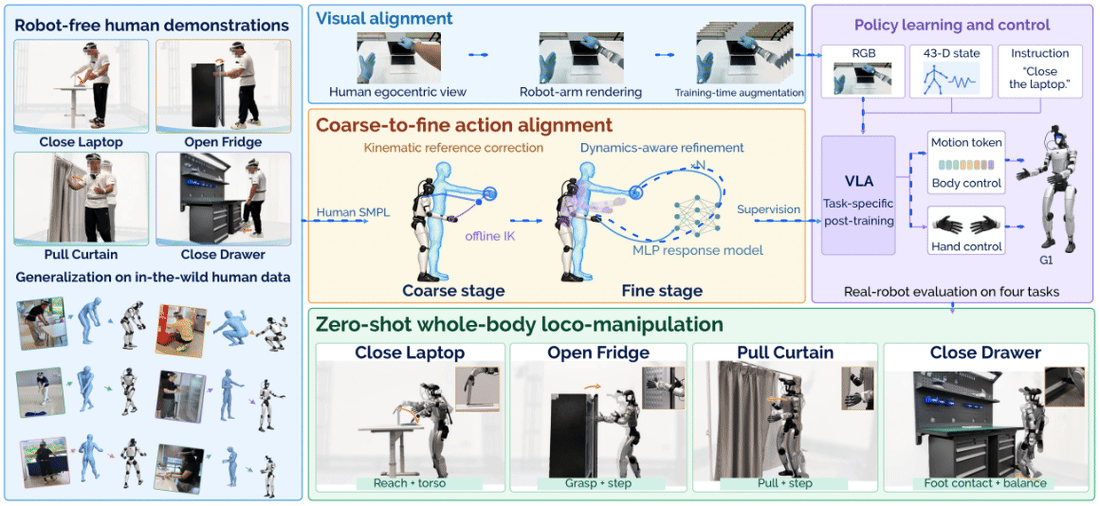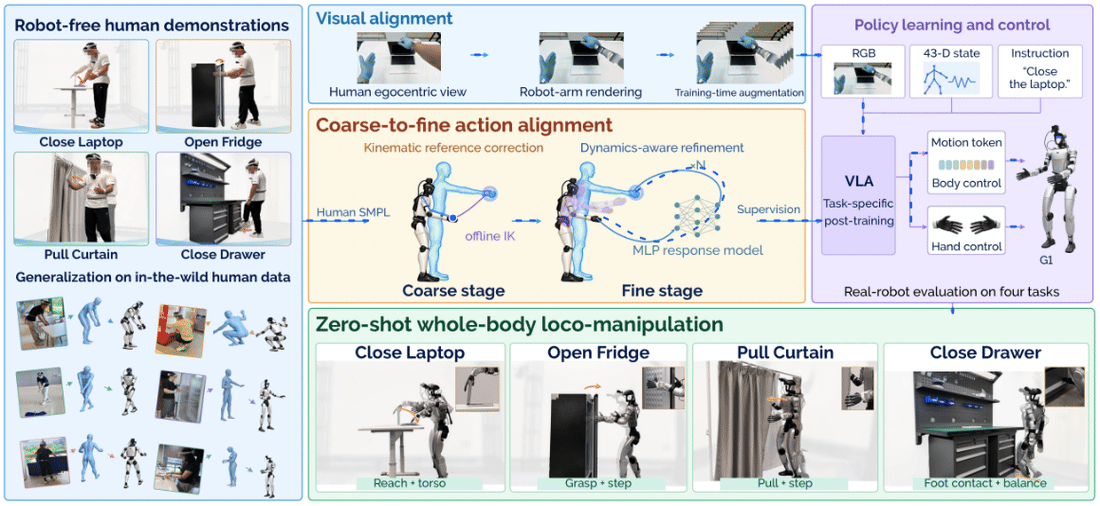
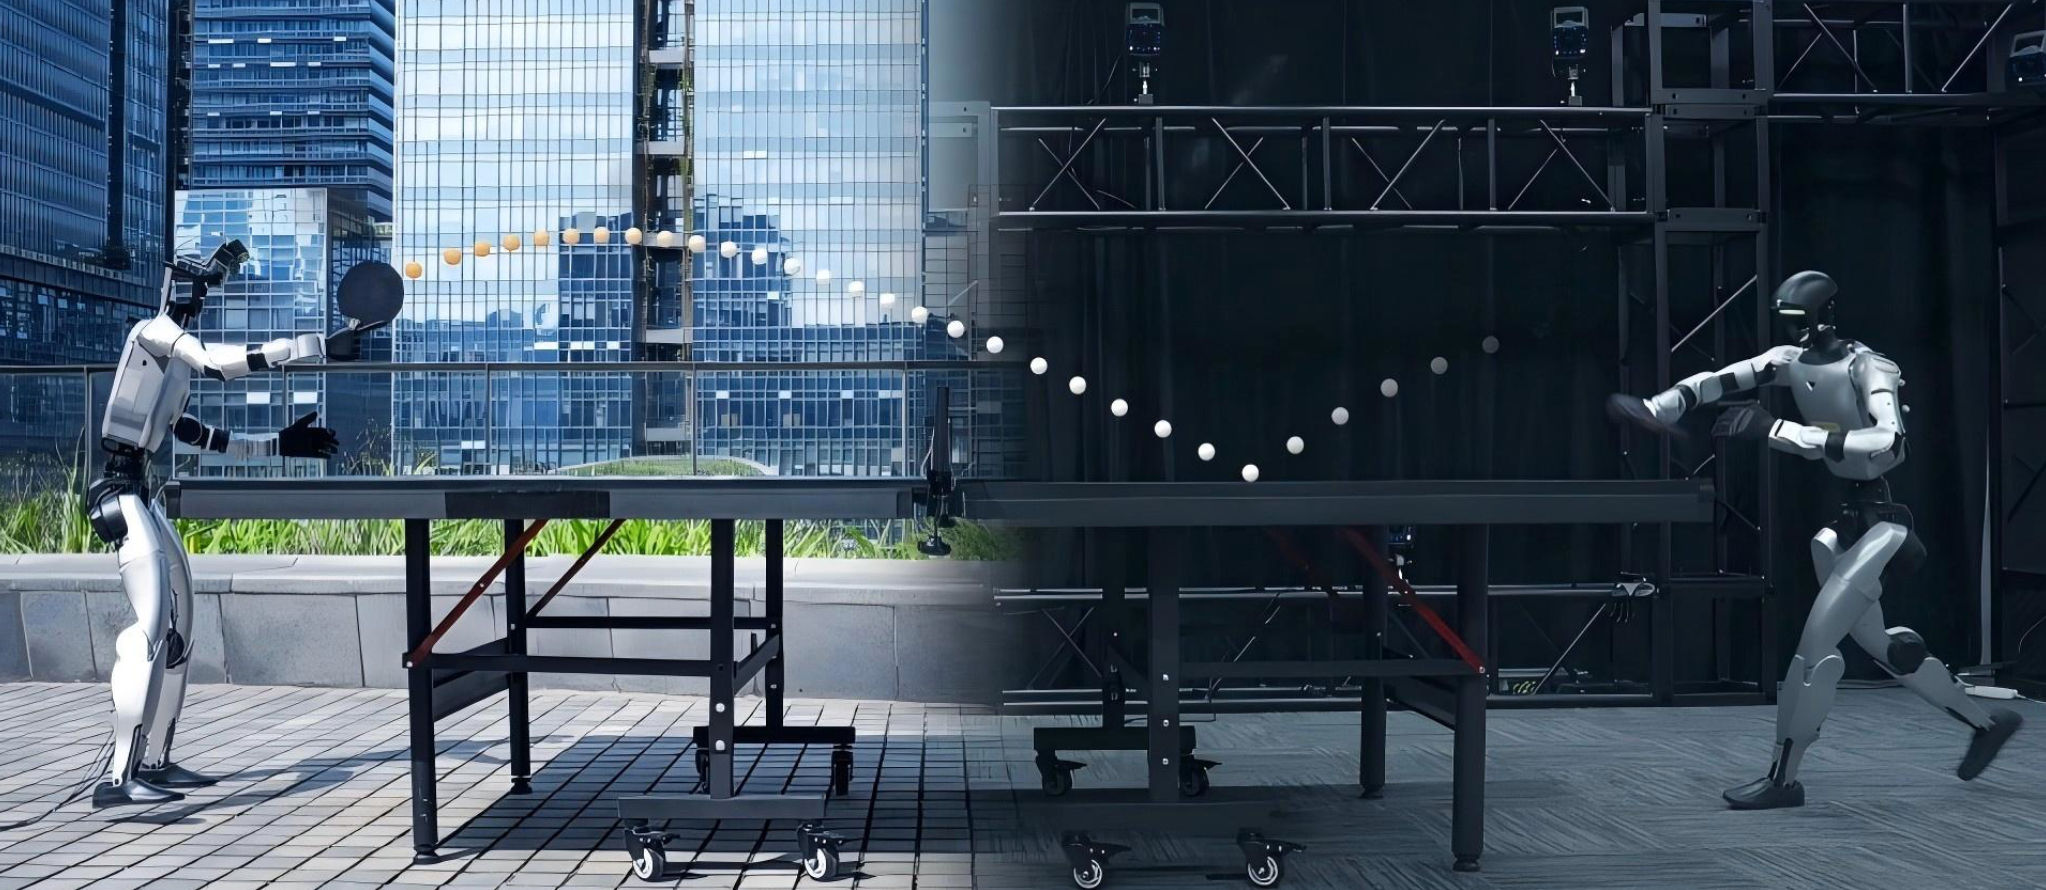
EgoHumanoid-V2: Human-to-Humanoid Transfer of Coordinated Whole-Body Skills for Loco-Manipulation
Egocentric human demonstrations transfer coordinated whole-body loco-manipulation skills to humanoids through coarse-to-fine action alignment and visual alignment, without target-task robot demonstrations.
2 / 8
Event 2026
AlpaSim E2E Closed-Loop Challenge 2026
A closed-loop benchmark for evaluating autonomous driving policies across safety, generalization, and computational efficiency.
3 / 8
CoRL 2026 Oral
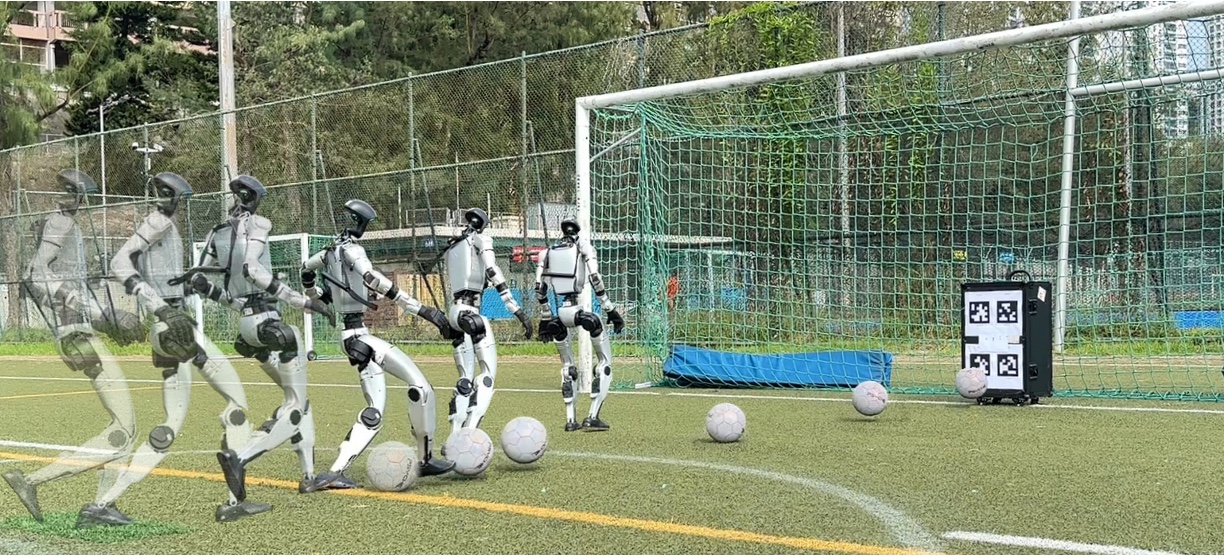
RoboNaldo: Accurate, Stable and Powerful Humanoid Soccer Shooting via Motion-Guided Curriculum Reinforcement Learning
World's first sub-meter accurate humanoid soccer shooting policy in general cases — single human reference, learn to track, then deviate and adapt.
4 / 8
Research Article 2026
World Engine: Towards the Era of Post-Training for Autonomous Driving
The missing infrastructure for Physical AI post-training in AD. Open-source. Production-validated.
2026.02.28
2026.10.09
2026.10.07

We are searching for talents from all over the world. Are you looking for opportunities? Don't hesitate to contact us via [email protected] or Dr. Hongyang Li.
- 具身智能研究員 / 自動駕駛研究員 / 機器人硬件工程師 / 科研助理 / 生態合作助理 【更多詳情】
- Ph.D. student / Research Assistant / Postdoc / etc. in Hong Kong and Shanghai
- Full-time employee and Intern (international are welcome)
Representative work published at top-tiered venues.
The missing infrastructure for Physical AI post-training in AD. Open-source. Production-validated.
Research Article 2026


Preprint 2026Position Paper
UniAD: The first comprehensive framework that incorporates full-stack driving tasks.


A novel generalist policy that leverages latent action representations to maximize data utilization, demonstrating predictable performance scaling with increased data volume.
IROS 2025 Best Paper Finalist


In this survey, we provide a comprehensive analysis of more than 270 papers on the motivation, roadmap, methodology, challenges, and future trends in end-to-end autonomous driving.
IEEE-TPAMI 2024Survey